
Description
VETUS V-CAN interface for tunnel bow thrusters – BPCANIN
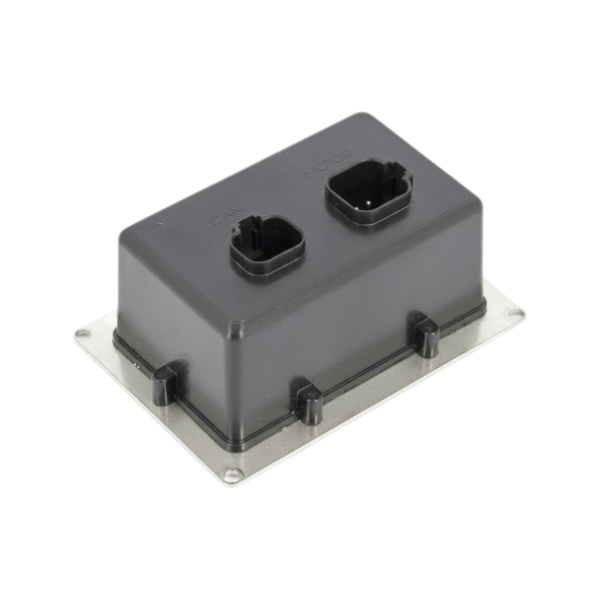
The VETUS BPCANIN is an electronic CAN interface for integrating a tunnel bow thruster into the digital VETUS V-CAN network. The module forms the connection between the bow thruster and the CAN bus system, allowing the thruster to be controlled from a suitable V-CAN control system.
The BPCANIN can be used, among other applications, within a VETUS V-Docker installation, where various manoeuvring systems work together via a central digital control system. The interface makes it possible to integrate a tunnel bow thruster into this communication network.
The module has separate connections for CAN and motor. This makes the BPCANIN a dedicated link between the digital V-CAN communication and the connected tunnel bow thruster.
Because the interface becomes part of a V-CAN network, the complete installation must be correctly configured using suitable V-CAN cabling and other required network components.
Key features and benefits
- CAN interface: Connects a tunnel bow thruster to the VETUS V-CAN network.
- For tunnel bow thrusters: Specifically designed for integration of this type of thruster.
- V-CAN compatible: Enables digital communication within a suitable VETUS system.
- CAN and motor connection: Equipped with separate connections for the network and bow thruster.
- V-Docker application: Can be used to integrate a tunnel bow thruster into a VETUS V-Docker system.
- Compact interface module: Designed for fixed installation as part of the electrical system.
Specifications
- Part number: BPCANIN
- Product type: CAN interface for tunnel bow thruster
- Accessory system: Bow thruster systems
- Network: V-CAN
- Application: Tunnel bow thrusters
- Connections: CAN and motor


 Get quick help via Whatsapp, click here!

Reviews
There are no reviews yet.